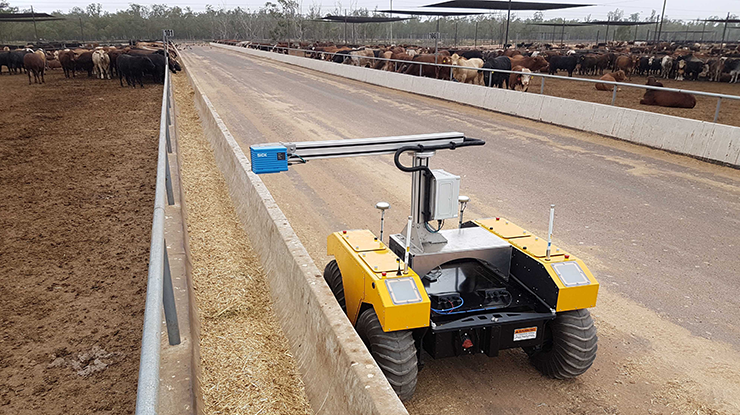
Industrial automation increasingly requires systems that can operate beyond paved roads and controlled facilities. From remote mine sites and agricultural fields to wetlands and winter test grounds, teams need mobile platforms that combine durability, payload... read more
Last month, Tony Baltovski, our Engineering Software Manager, and Adrian Popielas, our Mechanical Designer, sat down with Audrow Nash from The Sense Think Act Podcast to discuss TurtleBot 4 and ROS 2. TurtleBot 4 is the next generation of the world’s most... read more
We can’t get enough of TurtleBot 4 either! In this video, we set the bot to the task of delivering donuts to our incredible Turtlebot 4 development team! This video includes a full walkthrough of the mapping and navigation capabilities of the Turtlebot 4 mobile... read more
Navigating the ROS environment can be frightening and difficult for both seasoned and novice users. Our team has been hard at work creating new tools to assist ROS Developers in getting started with our robotic platforms and moving their research forward. Robot... read more
Welcome to our new video series in which we highlight some of the most unique and exciting robots from the Clearpath integration shop. In our first episode, we have a fully-loaded and autonomous Husky UGV outfitted with a Universal Robots UR5 arm, our Outdoor and... read more
Cameras and LiDAR sensors are known to fail in industrial areas with potentially harsh circumstances such as fog, dust, dirt, rain, etc. However, 3D imaging sonar sensors that use ultrasonic sound rather than light will continue to operate. For specific industries,... read more
Can’t wait to get your hands on a TurtleBot 4? Our Robotics Demo Designer, Maddy Thomson, walks you through unboxing & getting started with TurtleBot 4, including installing the Linux & Ros 2 environment, connecting the Raspberry Pi to WiFi, connecting... read more
By far one of our favourite conferences to attend is the IEEE International Conference on Robotics and Automation. We were excited to be back in person in Philadelphia for ICRA 2022 last month after two years of remote attendance or cancellations. We enjoyed not only... read more
Creating a safe, dependable, and robust control methodology for AGV autonomous navigation in unknown cluttered environments has long been recognized as a significant challenge. Such a navigation task requires the AGV to navigate safely and autonomously, to avoid... read more